NeuroMesh: distributed multi-agent swarm orchestrator.
A decentralized consensus and orchestration framework enabling autonomous LLM agent swarms to dynamically allocate complex computing tasks, recover from node failure, and synthesize verified multi-step proofs.
The Swarm.
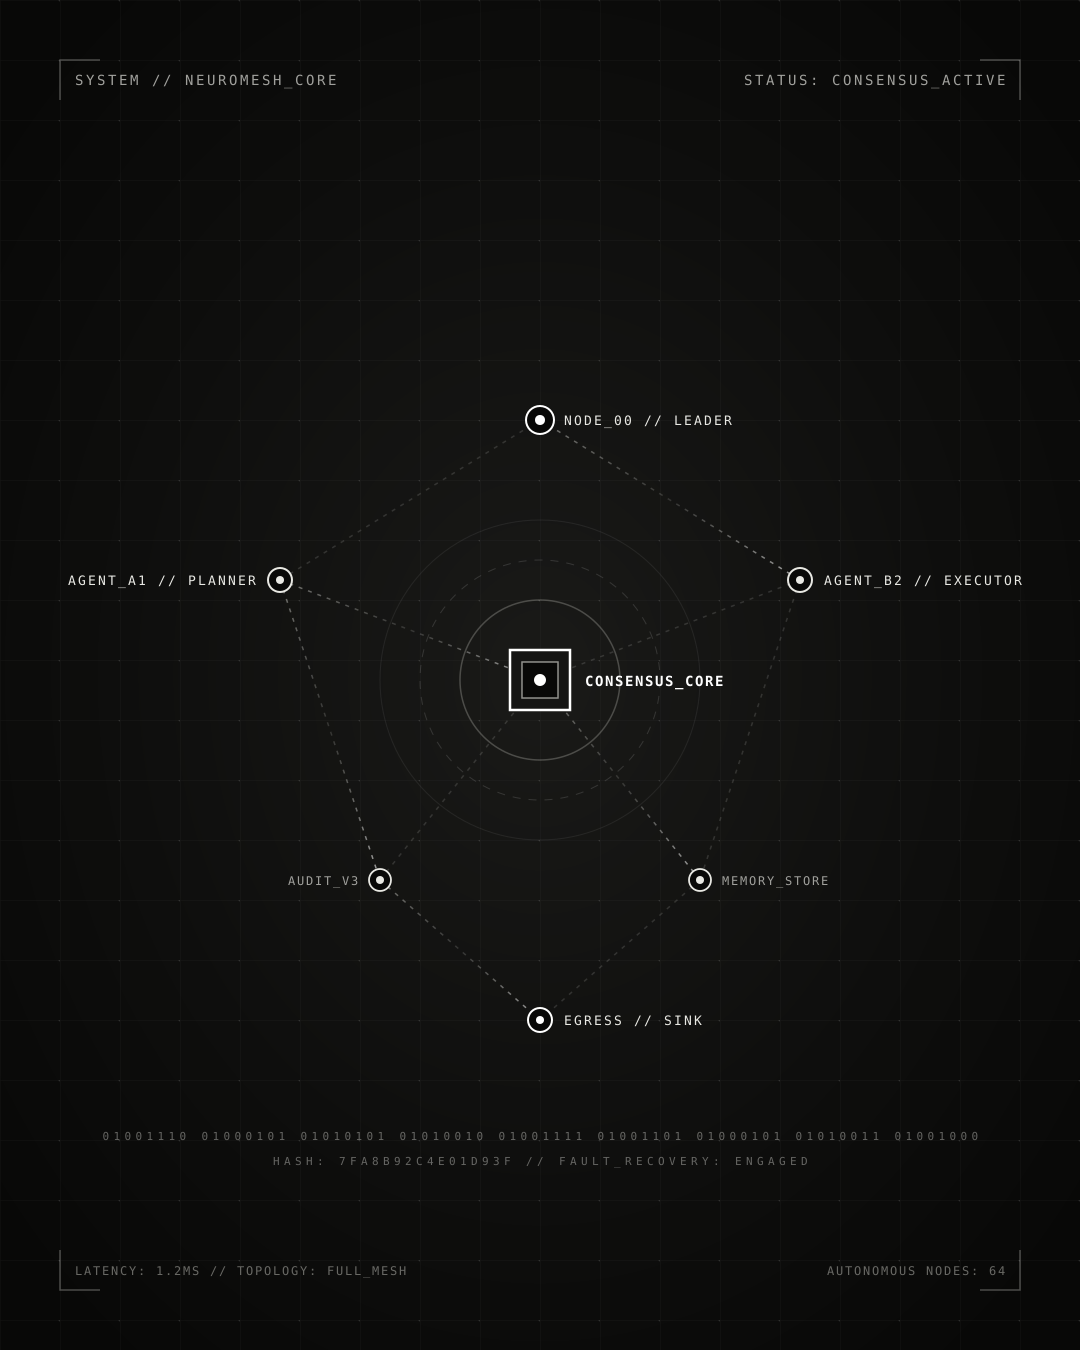
Single-agent AI systems collapse when task complexity exceeds model context bounds or API rate limits. NeuroMesh decomposes complex goals into directed acyclic graphs (DAGs) executed by specialized autonomous subagents.
Utilizing a modified lightweight Raft consensus algorithm, agents elect task coordinators, verify interim outputs via adversarial peer review, and auto-migrate state when an agent worker encounters network latency or unhandled exceptions.
The Bottleneck, The Solution.
Cascading Failure in Linear Chains
Sequential agent pipelines stop entirely if step 2 fails or outputs malformed JSON, wasting downstream token spend and stalling mission completion.
Dynamic Failover & Adversarial Verification
NeuroMesh isolates each execution node with a sandboxed transaction ledger. If validation tests fail, sibling agents dynamically re-route subtasks without breaking the parent graph.
Under The Hood.
